Single‑Phase Motor
IFLC = (HP × 746) / (V × η × PF)
Three‑Phase Motor
IFLC = (HP × 746) / (√3 × V × η × PF)
Where:
IFLC:The steady-state input current (line current) drawn by a single-phase AC motor when operating at its rated voltage, rated power, and rated load.
HP:The rated mechanical shaft output power of the motor, which represents the load power the motor is capable of driving.
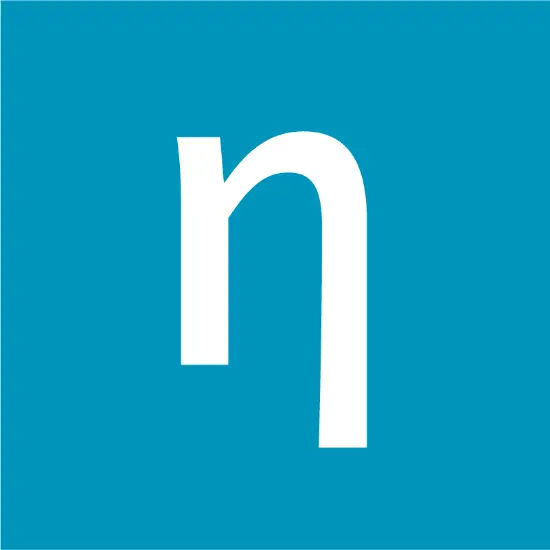
η:The ability of the motor to convert input electrical power into output mechanical power, reflecting the magnitude of energy losses (including copper losses, iron losses, mechanical losses, etc.).
PF:A parameter that reflects the phase difference between the voltage and current waveforms in an AC circuit, equal to the ratio of active power to apparent power.
Based on NEC 2023 Tables 430.247–430.250, this tool calculates the Full-Load Current (FLC) for motors under various voltages and power ratings, used for circuit breaker, fuse, and conductor sizing.
Input motor parameters to automatically retrieve NEC standard values:
Supports single-, two-, and three-phase systems
Supports HP and kW inputs
Real-time FLC calculation (A)
Compliant with NEC 2023
NEC FLC = Look-up value from tables
Example:
- Single-phase 240V, 1HP → FLC = 4.0 A
- Three-phase 480V, 1HP → FLC = 2.7 A
NEC FLC is typically higher than nameplate current
Must be used for protective device sizing
Not applicable to VFD-driven motors
Voltage must be standard
NEC Tables vs. Nameplate Ratings: NEC rules specify that standardized table values must be used for conductor sizing and circuit protection (to ensure safety for the lowest-efficiency motor of that HP). Nameplate current is used primarily for setting thermal overload relays.
Locked Rotor Amps (LRA) / Inrush Current: Full-Load Current represents steady-state running current under maximum rated output. Locked Rotor Current during Direct-On-Line (DOL) starting is typically 6 × to 8× higher than IFLC
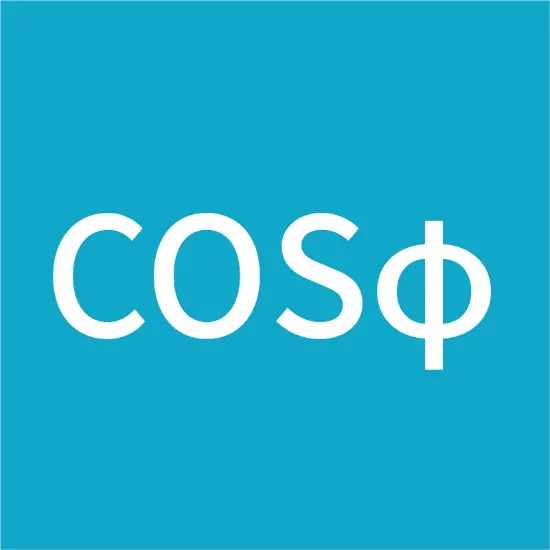
Default Parameter Benchmarks: If efficiency (η) or power factor (cos∅) are unknown, standard industry estimates are η≈ 0.85-0.93 (for 1–50 HP standard induction motors) and cos∅ ≈ 0.85
This tool works on ideal sine‑wave assumptions and outputs theoretical reactive‑power values only. Harmonic distortion and line losses are not considered.
For real‑world compensation design, use on‑site power‑quality‑analyzer readings and prevent over‑compensation.

 Login